Daniel Lam

Computer Science, The University of Texas at Austin. BS expected May 2028.

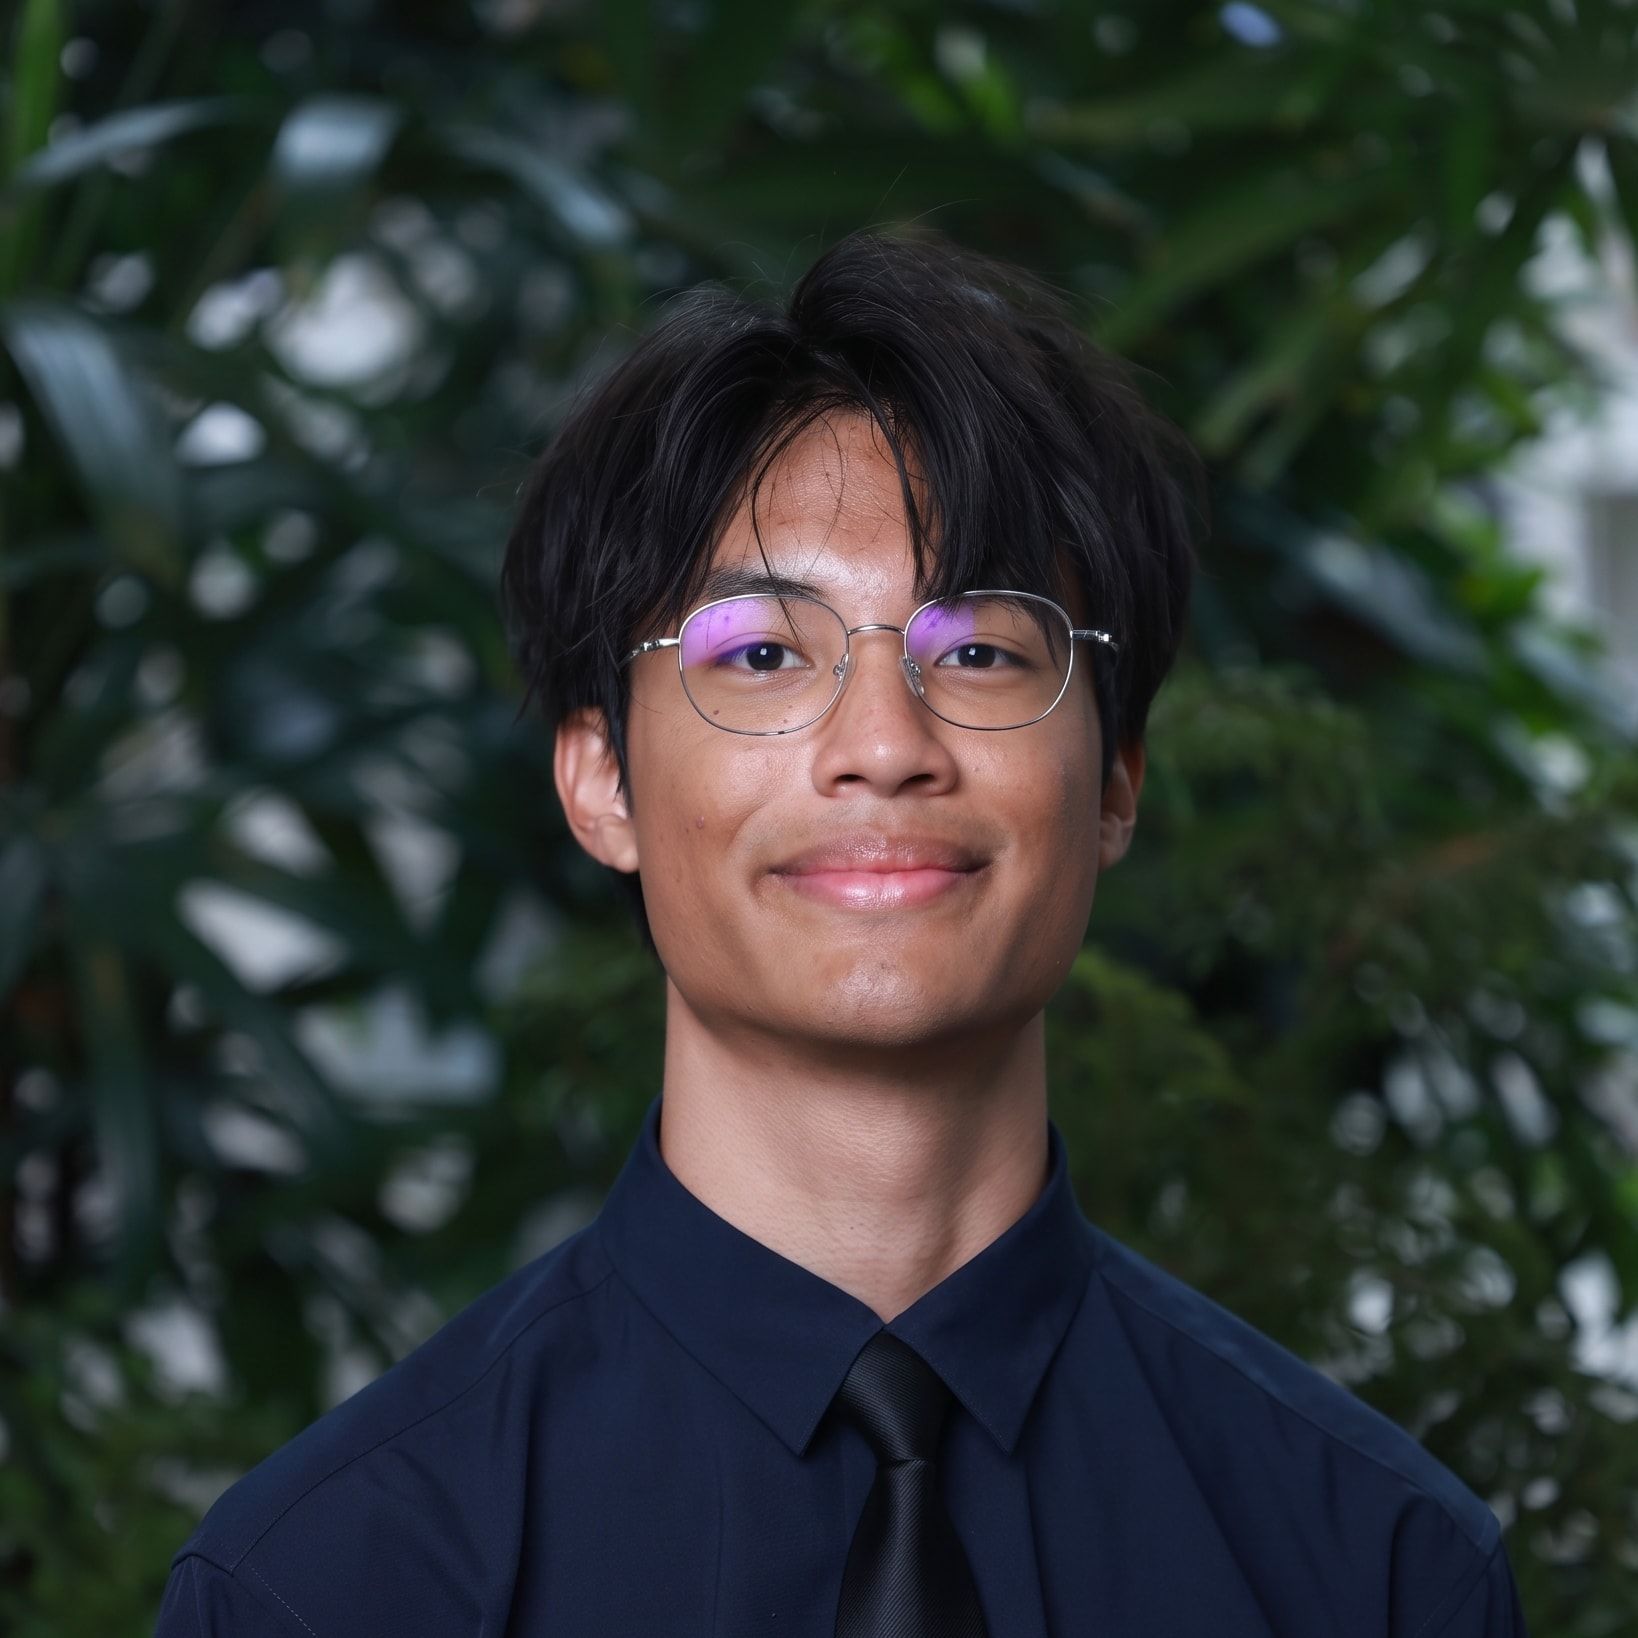
Portrait of Daniel Lam

Daniel Lam

Computer Science, UT Austin, May 2028Research Assistant, RobIn Lab

I work where robot learning meets production AI software.

I'm a computer science student at UT Austin concentrating in AI and robotics. In the Robotic Interactive Intelligence Lab with Prof. Roberto Martín-Martín, I study how robots can manipulate objects without breaking them, and I led the RoboCasa implementation of OopsieVerse (RSS 2026).

On the engineering side I build AI agents that ship: voice and multi-agent planning on Salesforce Agentforce in summer 2026, and LLM developer tools for simulation engineers at Lockheed Martin in 2025.

I also lead simulation for Texas Marine Robotics' RoboBoat 2027 boat and mentor new researchers through Texas Robotics. Off the clock I travel with a camera; those photos live on the Shots page.

Recent

  • OopsieVerse accepted to RSS 2026.
  • Joined Salesforce Agentforce as a software engineer intern.
  • Started leading simulation for Texas Marine Robotics.
  • Became a peer mentor for robot learning at Texas Robotics.

Research

Robot manipulation safety, simulation, and perception.

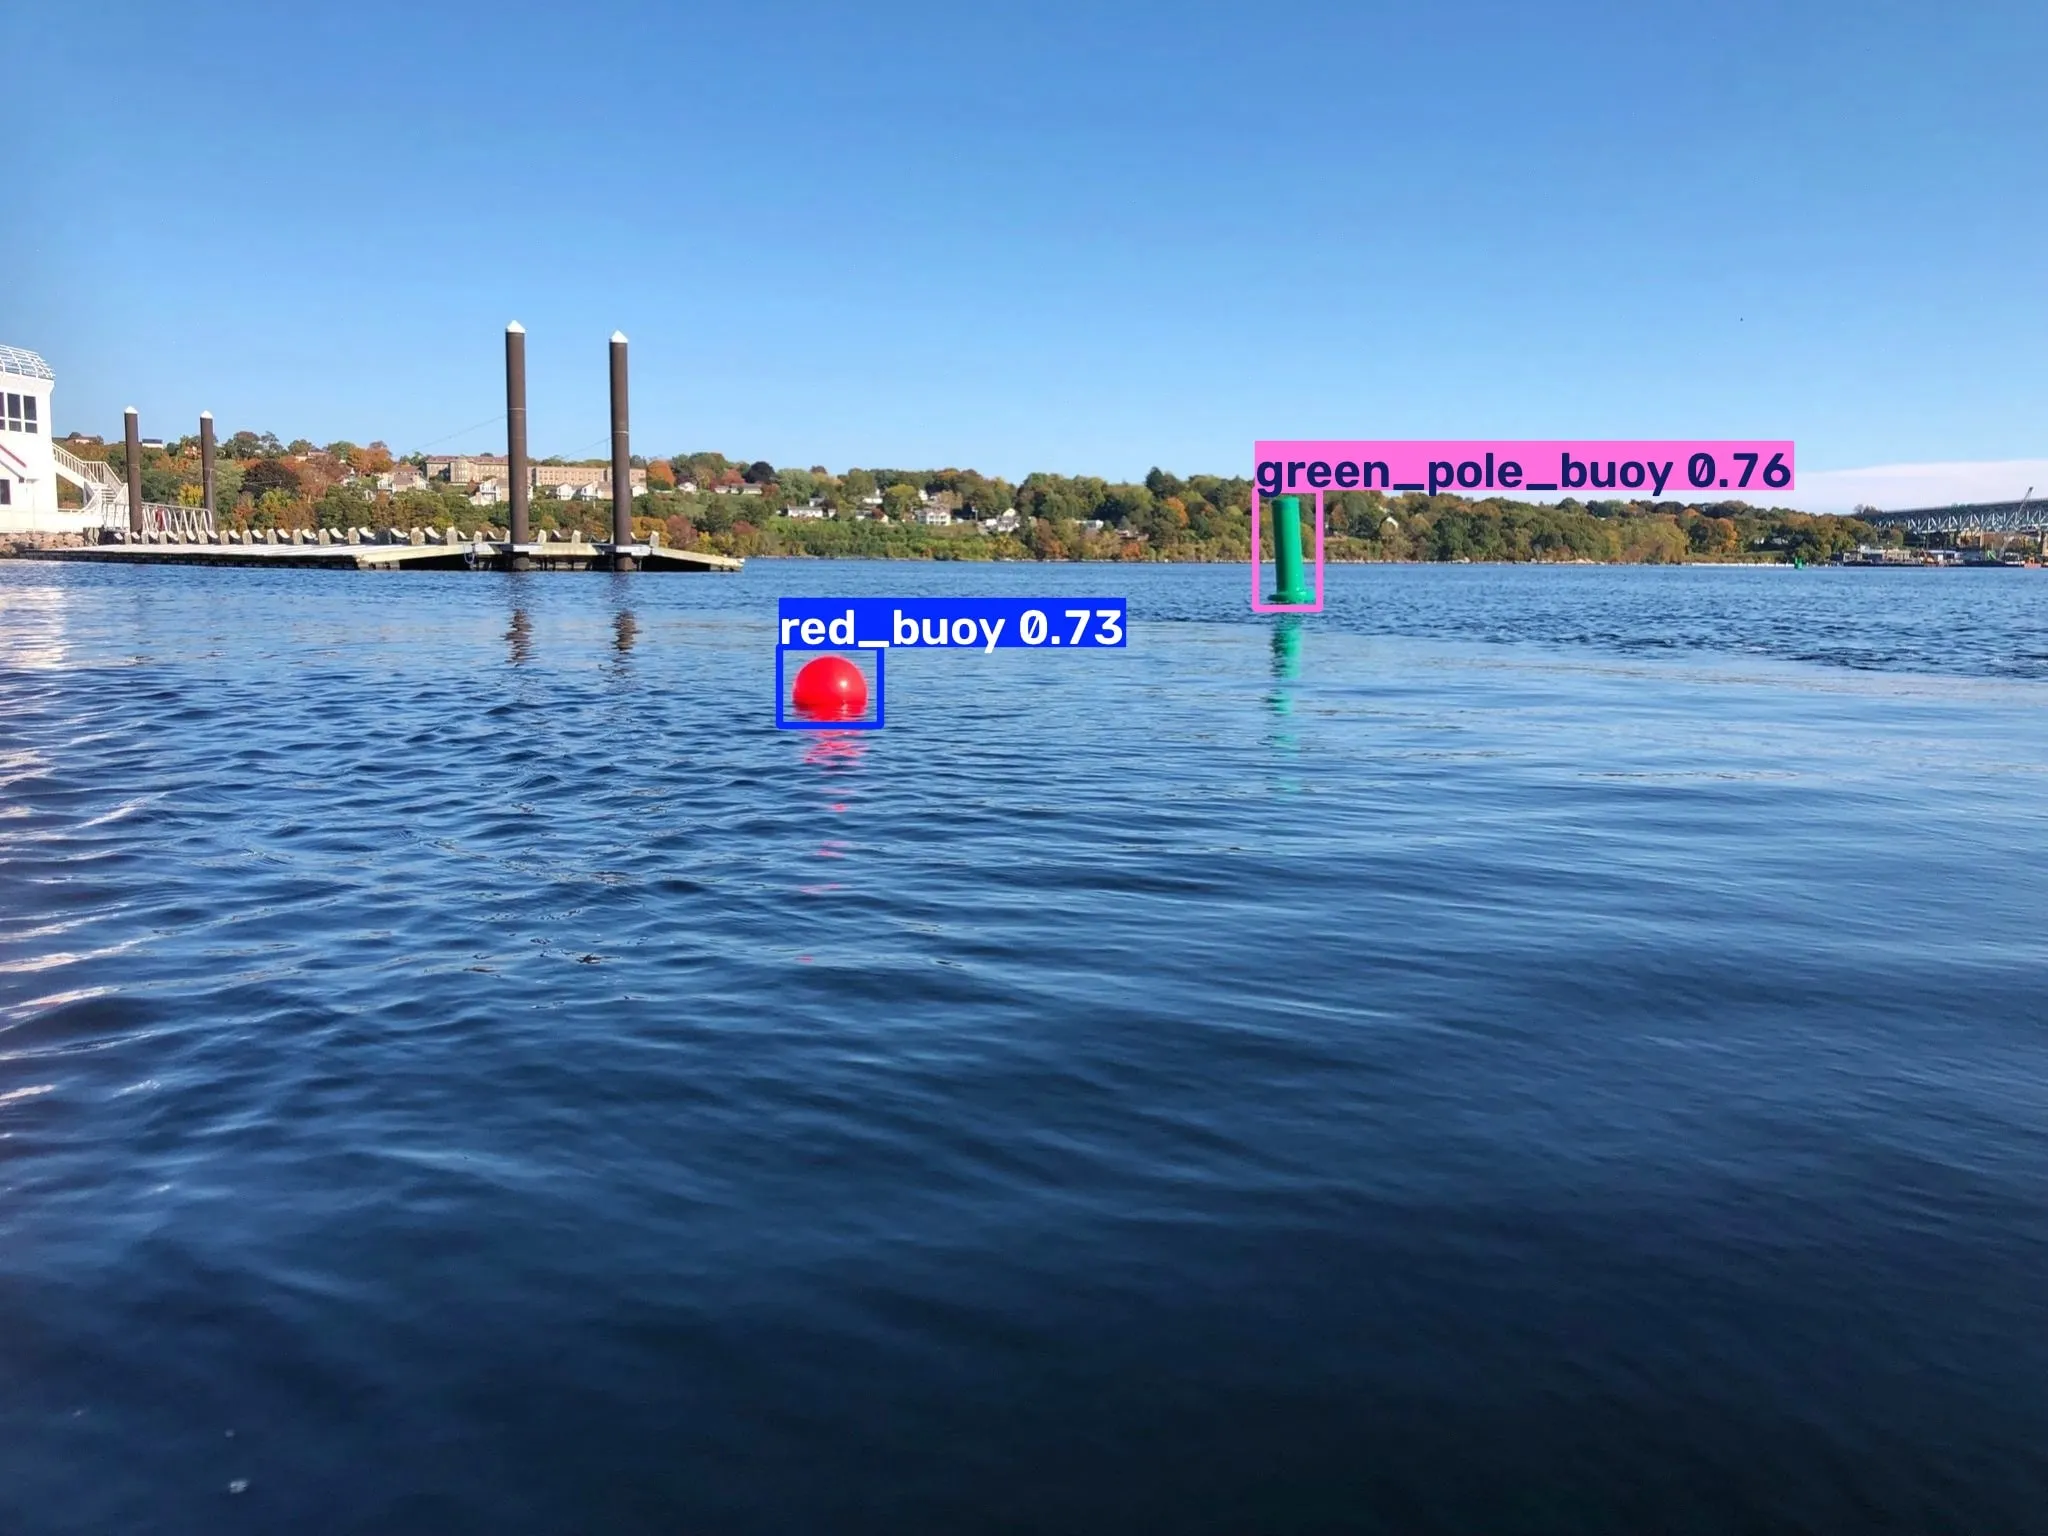
Harbor water with a red ball buoy and a green pole buoy, each boxed and labeled by the detector with its confidence

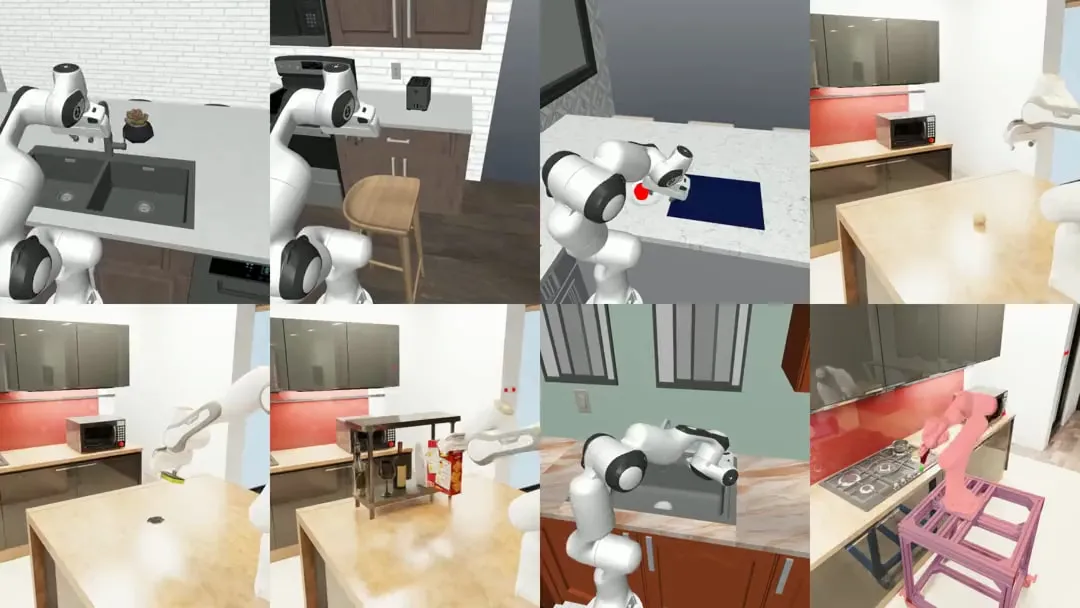
OopsieVerse overview. Video: RobIn Lab

OopsieVerse overview. Video: RobIn Lab
RSS 2026 Paper

OopsieVerse: A Safety Benchmark with Damage-Aware Simulation for Robot Manipulation

Arnav Balaji*, Arpit Bahety*, Sriniket Ambatipudi, Daniel Lam, Junhong Xu, Roberto Martín-Martín

A simulator-agnostic framework that turns contact forces, heat, and liquid into measurable damage, plus 32 household tasks that pit easy-but-risky strategies against careful ones.

My part Led the RoboCasa implementation: 23 damageable objects, 16 kitchen environments, and 15 long-horizon tasks with staged subgoal checks.

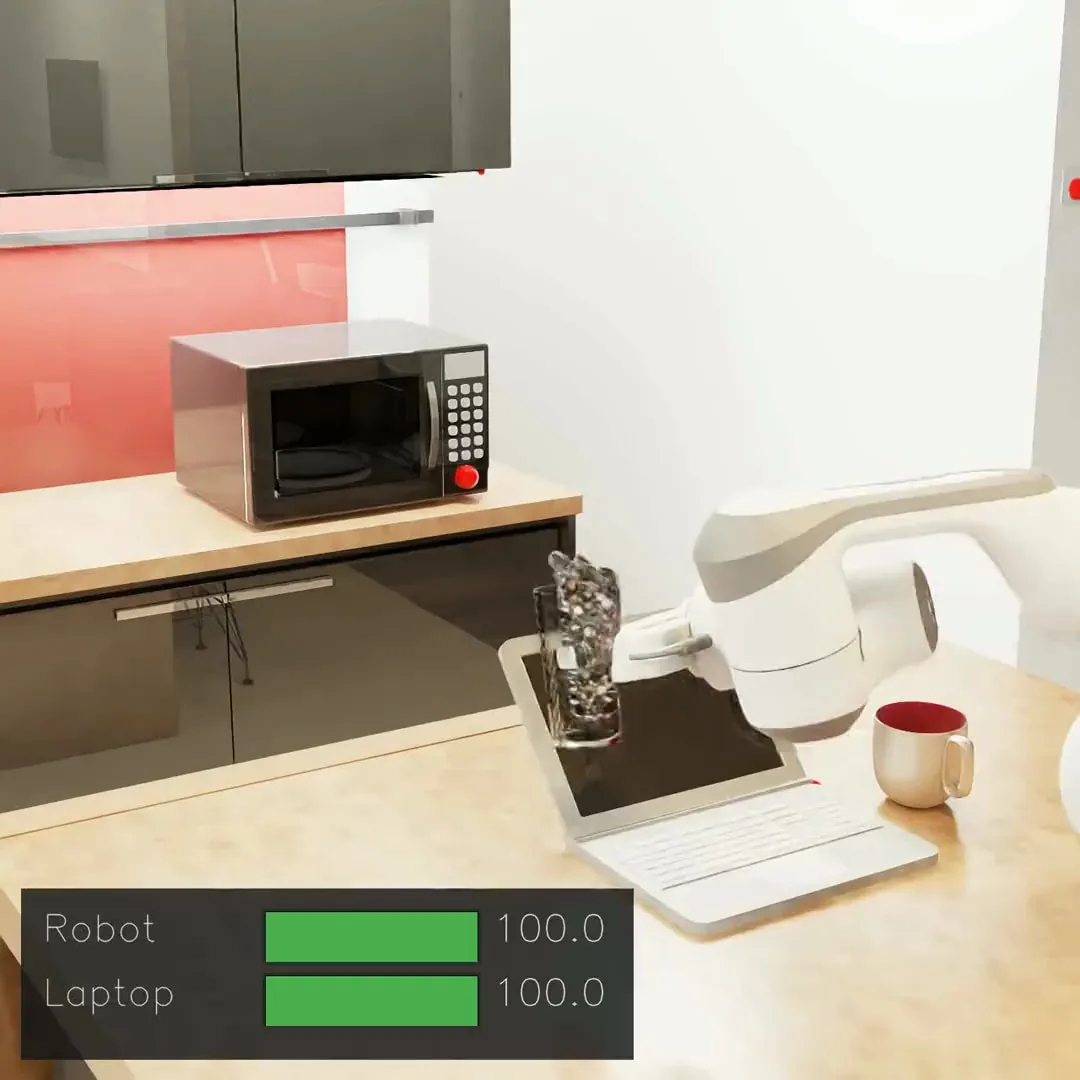
Damage-aware data collection. Video: RobIn Lab
OopsieVerse Data collection

A real-time damage HUD for safer demonstrations

An OpenCV heads-up display that shows teleoperators each object's live health while they record. It made 450+ safety-annotated demonstrations across 32 tasks possible, and damage-aware imitation learning trained on them cut real-world damage on a Franka Panda by 60%.

Harbor water with a red ball buoy and a green pole buoy, each boxed and labeled by the detector with its confidence
Buoy detections on a test photo.
Texas Marine Robotics In progress

Synthetic buoy data for RoboBoat 2027

Rendering full course scenes in NVIDIA Isaac Sim to auto-label buoy images, so the detector on the boat's Jetson Nano trains without on-water labeling.

Publications

RSS 2026
OopsieVerse: A Safety Benchmark with Damage-Aware Simulation for Robot Manipulation. A. Balaji*, A. Bahety*, S. Ambatipudi, D. Lam, J. Xu, R. Martín-Martín. Robotics: Science and Systems, 2026. * equal contribution

Experience

Production AI at Salesforce and Lockheed Martin, research at UT Austin.

Salesforce

Software Engineer Intern, Agentforce Jun - Aug 2026 San Francisco

Voice and multi-agent planning for Agentforce.

  • Voice agent latency from 3.9s to 951ms (76% faster) with split model routing
  • Group restaurant planning from 30 minutes to under 2 with a multi-agent LangGraph pipeline
  • Top 5 of 2,000 restaurants in under 2s with zero diet or location errors, using pgvector and SQL

Lockheed Martin

Software Engineer Intern, Modeling & Simulation May - Aug 2025 Fort Worth

LLM tools for simulation engineers, and F-16 display software.

  • 23% faster code completion for 18 engineers with a VS Code assistant on Llama 3.3 70B and MCP
  • 80% faster documentation lookup with a RAG assistant serving 50+ daily queries
  • 15% faster display data processing across 29 countries from 5 F-16 JHMCS features in C/C++

RobIn Lab, UT Austin

Robotics Research Assistant Jan 2025 - now Austin

Robot manipulation safety with Prof. Roberto Martín-Martín.

  • Led the RoboCasa build of OopsieVerse (RSS 2026) across 23 objects and 16 kitchens
  • Authored 15 long-horizon manipulation tasks with staged subgoal checks
  • Cut real-world damage 60% with damage-aware imitation learning on a Franka Panda

Texas Robotics

Peer Mentor, Robot Learning 2026 - now Austin

Mentoring 12 first- and second-year researchers; selected for a second term.

  • Onboarded 3 undergraduate researchers onto my own project
  • Teaching rigid-body kinematics and motion planning through hands-on projects

Sustainable Building Initiative

Director of Internal Technologies Aug 2024 - Aug 2026 Austin

Led a 12-person team building the organization's AI member portal.

  • 23% better retrieval accuracy from hybrid vector and keyword search in pgvector
  • 50% faster project delivery across a $200M portfolio

Projects

Things I built on my own time.

Coding Research Agent

A CLI agent that finds, compares, and analyzes developer tools.

LangGraph, Claude API, Firecrawl, MCP

2025

Choose Your Adventure

An AI story generator with branching narratives and async job processing.

React, FastAPI, PostgreSQL, Claude API

2025

Email automation on GCP

A serverless pipeline that replaced manual data entry for 60+ new member signups.

Cloud Run Jobs, Cloud Scheduler, Sheets API, GitHub Actions

2025

Shots

Travel and everyday photos.

Station platform at dusk
Photo: taro ohtani
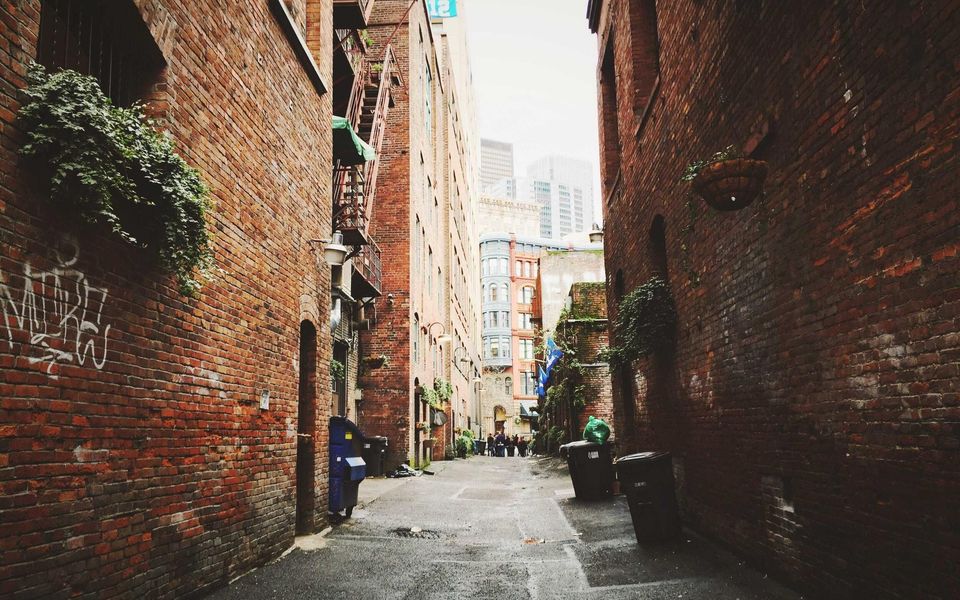
Brick alley
Photo: sergee bee
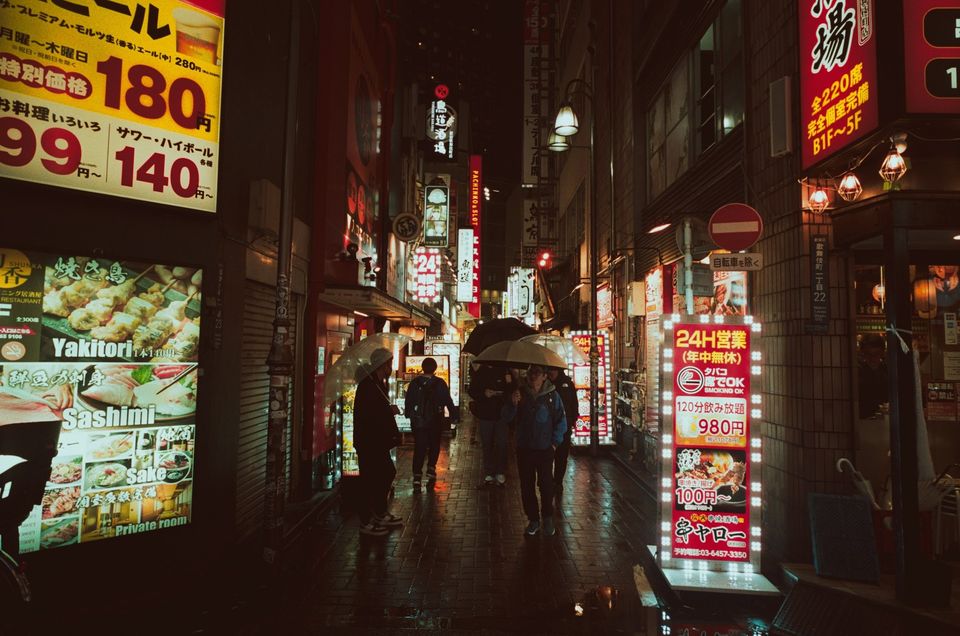
Rainy alley in Shinjuku
Photo: Intrepid (@intrepidfilm)
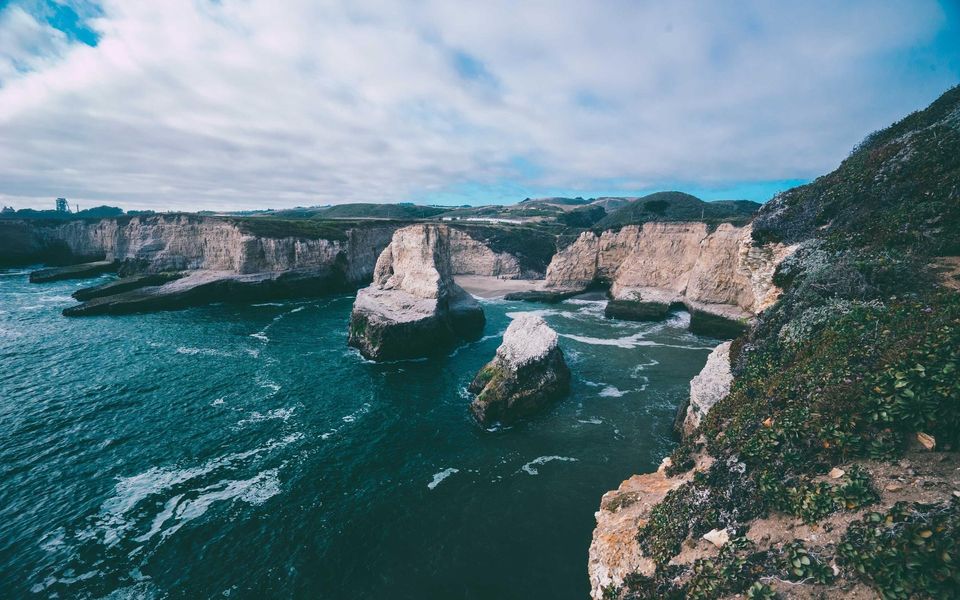
Coastline
Photo: Joseph Barrientos

Get in touch.

I read everything. Email is the fastest way to reach me.

daniel.wingchi.lam@gmail.com